
- New
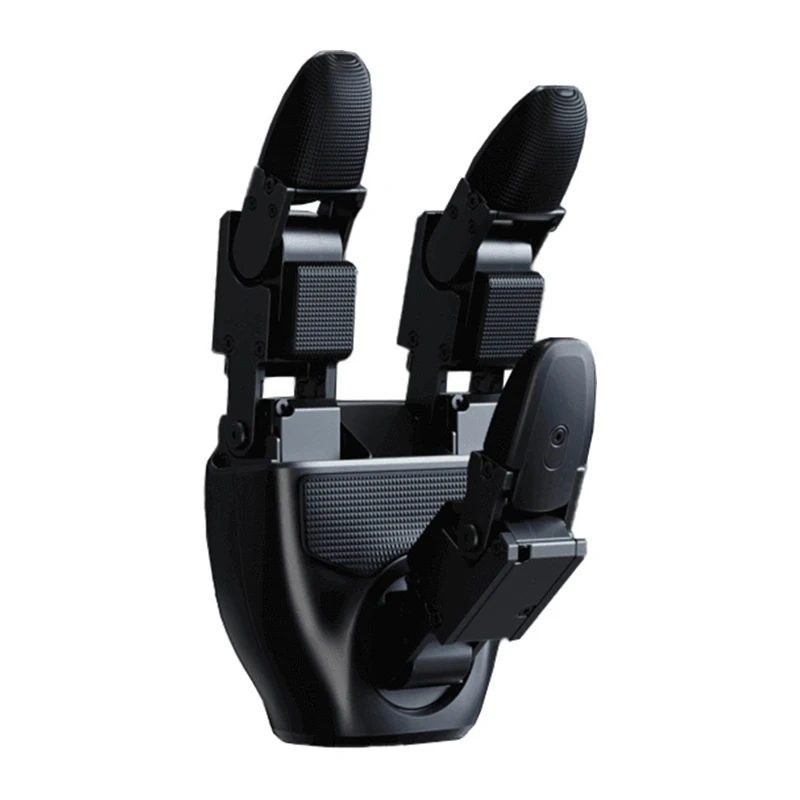
UNITREE DEX3WT-214T - a pair of left and right three-fingered robotic hands for the UNITREE G1 humanoid robot. Each hand has 7 degrees of freedom, 33 pressure sensors, weighs 710 g, supports USB 2.0 communication at a frequency of up to 1,000 Hz, and force and position control.
UNITREE DEX3WT-214T - a pair of left and right three-fingered robotic hands for the UNITREE G1 humanoid robot. Each hand has 7 degrees of freedom, 33 pressure sensors, weighs 710 g, supports USB 2.0 communication at a frequency of up to 1,000 Hz, and force and position control.
Guarantee
24 month
Delivery from Europe in
8 - 9
business days
UNITREE DEX3WT-214T - a pair of left and right three-fingered robotic hands for the UNITREE G1 humanoid robot. Each hand has 7 degrees of freedom and 33 pressure sensors. One hand weighs 710 g, uses USB 2.0 communication at a frequency of up to 1,000 Hz and supports force and position control.
Product information | |
|---|---|
| Product type | A pair of three-fingered robotic hands |
| Manufacturer | UNITREE |
| Model | DEX3WT-214T |
| Configuration | Left and right hands |
| Compatibility | Humanoid robot UNITREE G1 |
Mechanical specifications | |
| Finger configuration | Thumb, index finger, and big toe |
| Degrees of freedom | Thumbs: 3; index fingers: 2; big toes: 2 on each hand |
| Drive mechanism | 6 direct drive motors and 1 gear drive motor in each brush |
| Joint range of motion | Thumbs: −60° to 60°, −35° to 60°, and 0° to 100° Index finger: 0° to 90° and 0° to 100° Big toe: 0° to 90° and 0° to 100° |
| Fingertip position repeatability | ±2mm |
| 175 × 88 × 77 mm for one extended hand | |
| Weight | 710 g per hand |
Touch sensing system | |
| Pressure sensors | 33 in one hand; 66 sensors in a pair |
| Sensor arrays | 9 in one hand |
| Sensor layout | Three 2×2 palm matrices, three 2×2 finger pad matrices, and three 3×1 fingertip matrices on each hand |
| Pressure detection range | 10-2 500g |
| Maximum sensor load | 20 kg without damage |
| Sensor feedback | Pressure value and sensor temperature |
Control and communication | |
| Management method | Hybrid force and position control |
| Communication interface | USB 2.0 |
| Communication frequency | 1,000 Hz |
| Joint connection | High Speed Unibus |
| Data packet size | Transmitting 1,234 bytes, receiving 1,270 bytes |
| Supported control parameters | Torque, angle, angular velocity, stiffness and damping |
| Feedback data | Joint mode, position, speed, torque and temperature; voltage, current, pressure, sensor temperature and IMU data |
Electrical and usage specifications | |
| Operating voltage | 12-58V |
| Standby current | 0.2 A at 58 V |
| Maximum current | 10 A |
| Operating temperature | From −20°C to 60°C |
| Lifting capacity | Up to 500 g when gripping a hard round object with a diameter of 5 cm under the specified test conditions |
Safety warning | |
| Use only with compatible UNITREE G1 equipment and appropriate control software. Use the hands within the specified voltage, temperature, and load limits. Keep fingers and objects away from moving joints during operation, and disconnect power before installation, maintenance, or adjustment. This product is intended for robotics research and object control applications; it is not a stand-alone replacement for the human hand, and is not a medical device. | |
| Height | 150mm |
| Length | 200mm |
| Weight | 950g |
| Width | 120mm |